Competition Robotics / Mechanism Design
FRC Rack-and-Pinion Intake
Overview
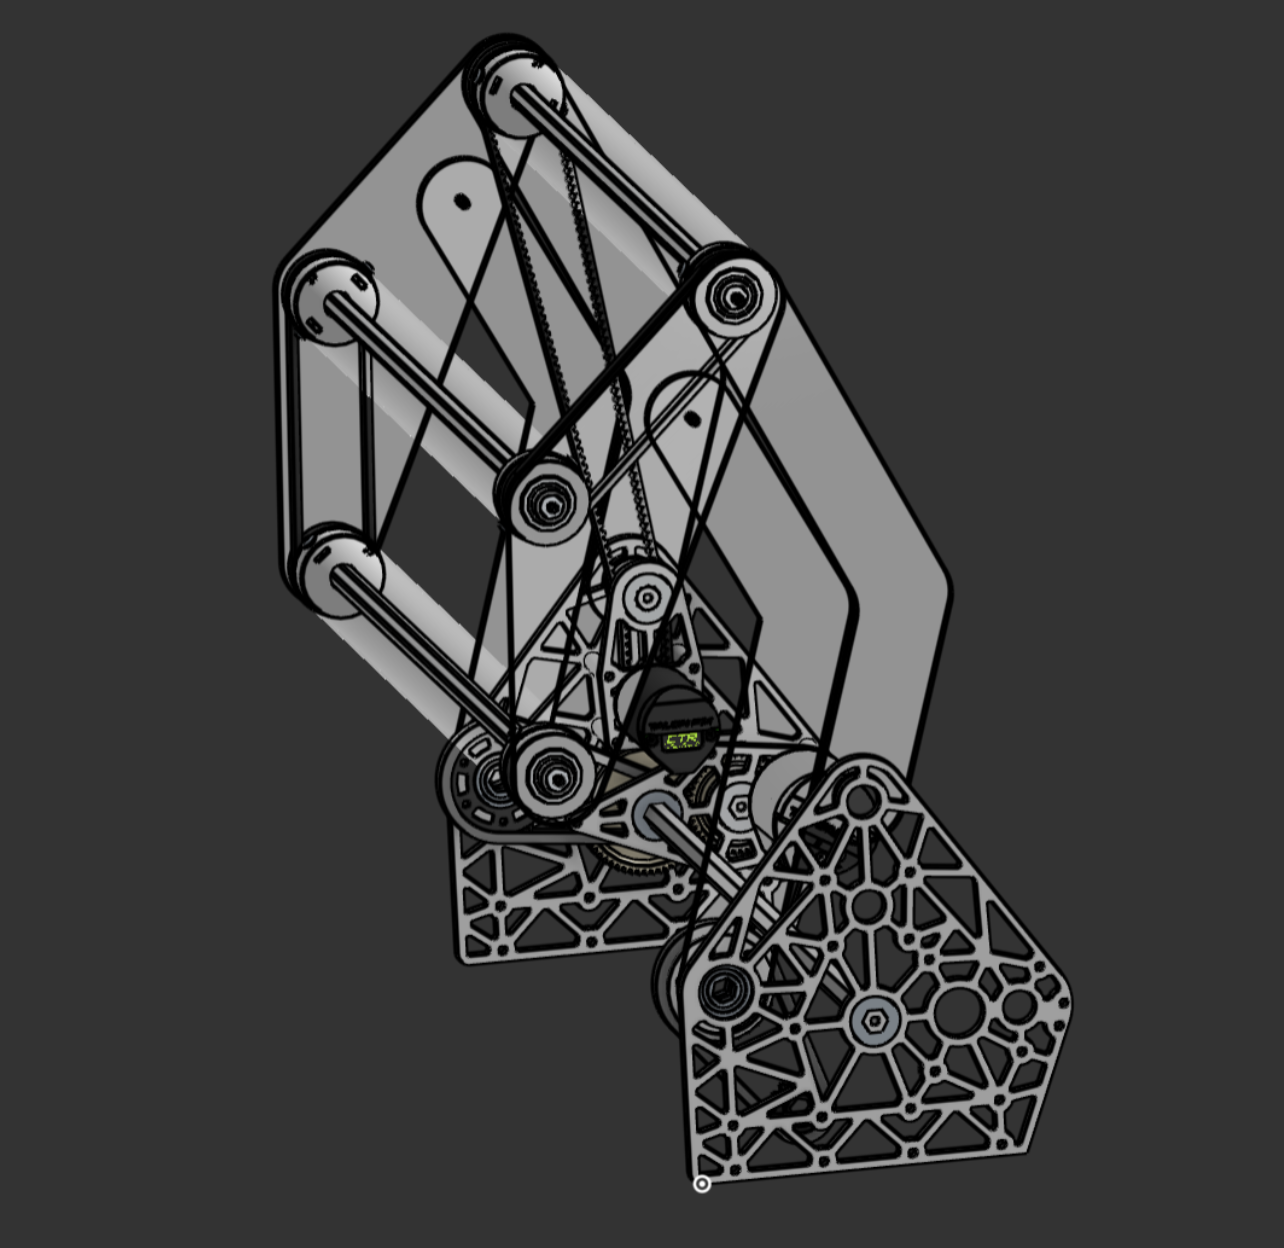
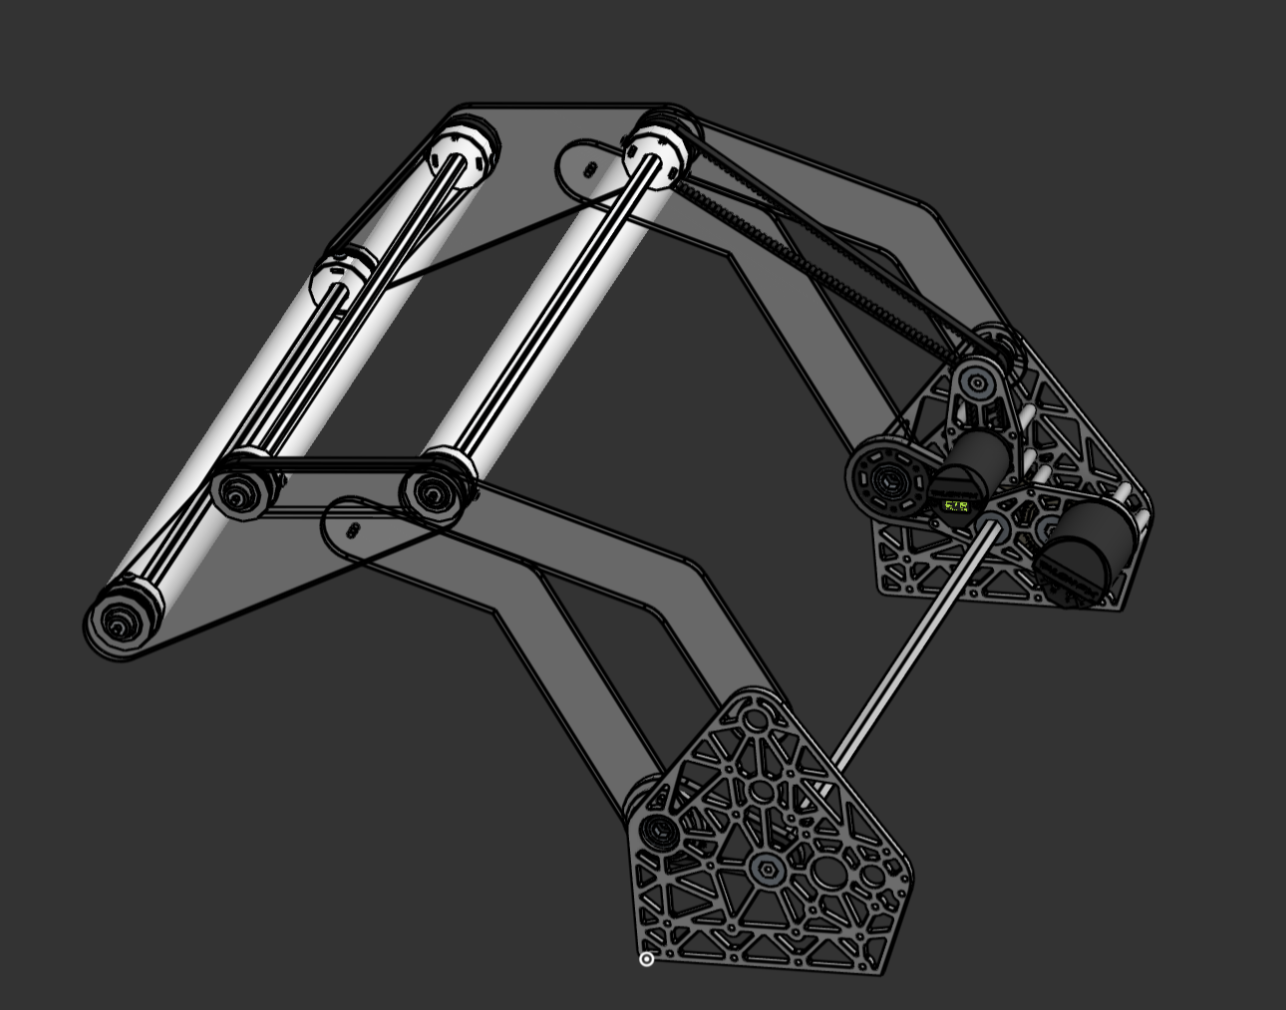
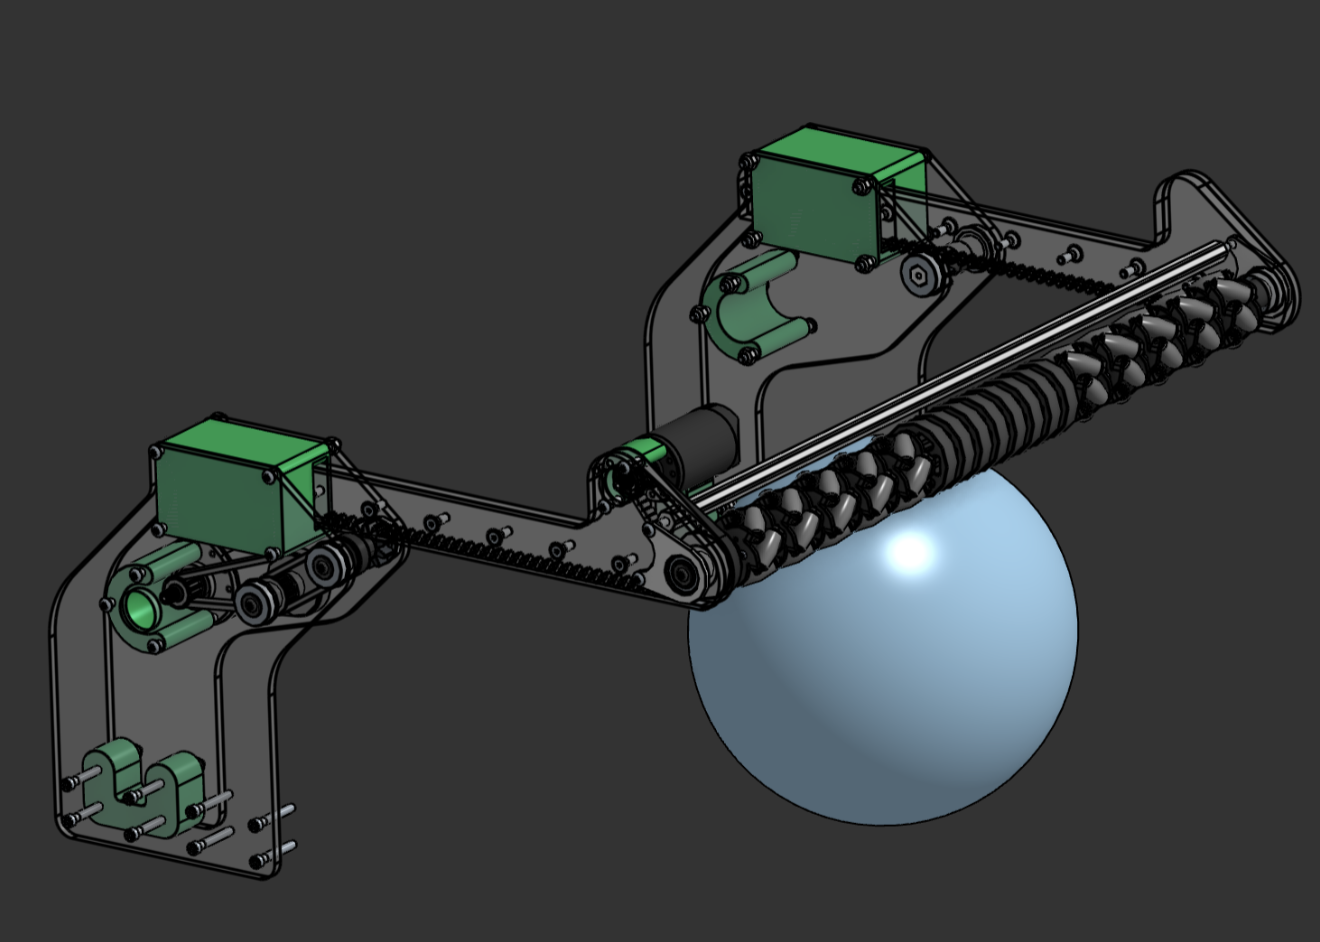
Designed a rack-and-pinion intake mechanism for an FRC competition-style robot, creating a compact system that could extend the intake outward to acquire game pieces and retract it back into the robot when not in use.
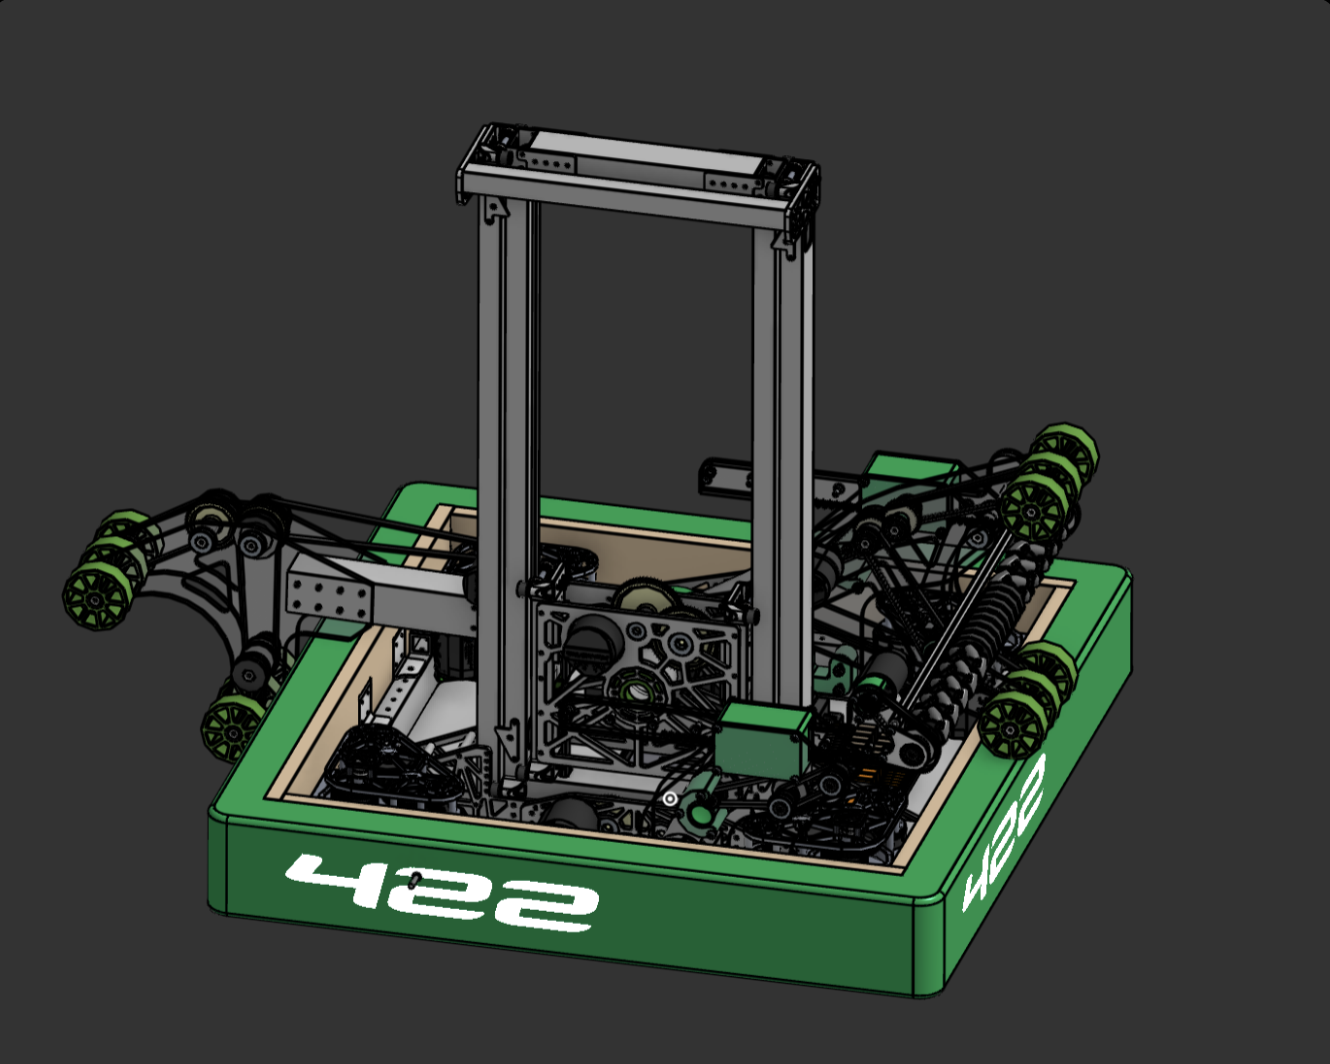
I developed the mechanism in CAD and integrated the rack-and-pinion drive, belt-driven rollers, motors, bearings, and structural plates around the robot's existing geometry. The design required balancing reach, packaging space, rigidity, and reliable motion while ensuring the intake could deploy consistently under competition conditions. I also worked through component placement and mechanical integration so the system could fit within the larger robot assembly without interfering with surrounding subsystems.
Design Goals
- Extend outward far enough to acquire game pieces
- Retract into the robot when not in use
- Fit within a crowded robot architecture
- Maintain structural rigidity
- Deploy consistently
- Integrate with surrounding robot subsystems
- Package motors, belts, bearings, and structural components efficiently
Mechanical Design
- Rack-and-pinion linear deployment
- Belt-driven intake rollers
- Motors
- Bearings
- Structural side plates
- Roller shafts
- Mounting hardware
- Subsystem interfaces to the robot chassis
Robot Integration
The intake mechanism integrated into the full robot assembly.