Competition Robotics / Mechanism Design
FRC Four-Bar Intake
Overview
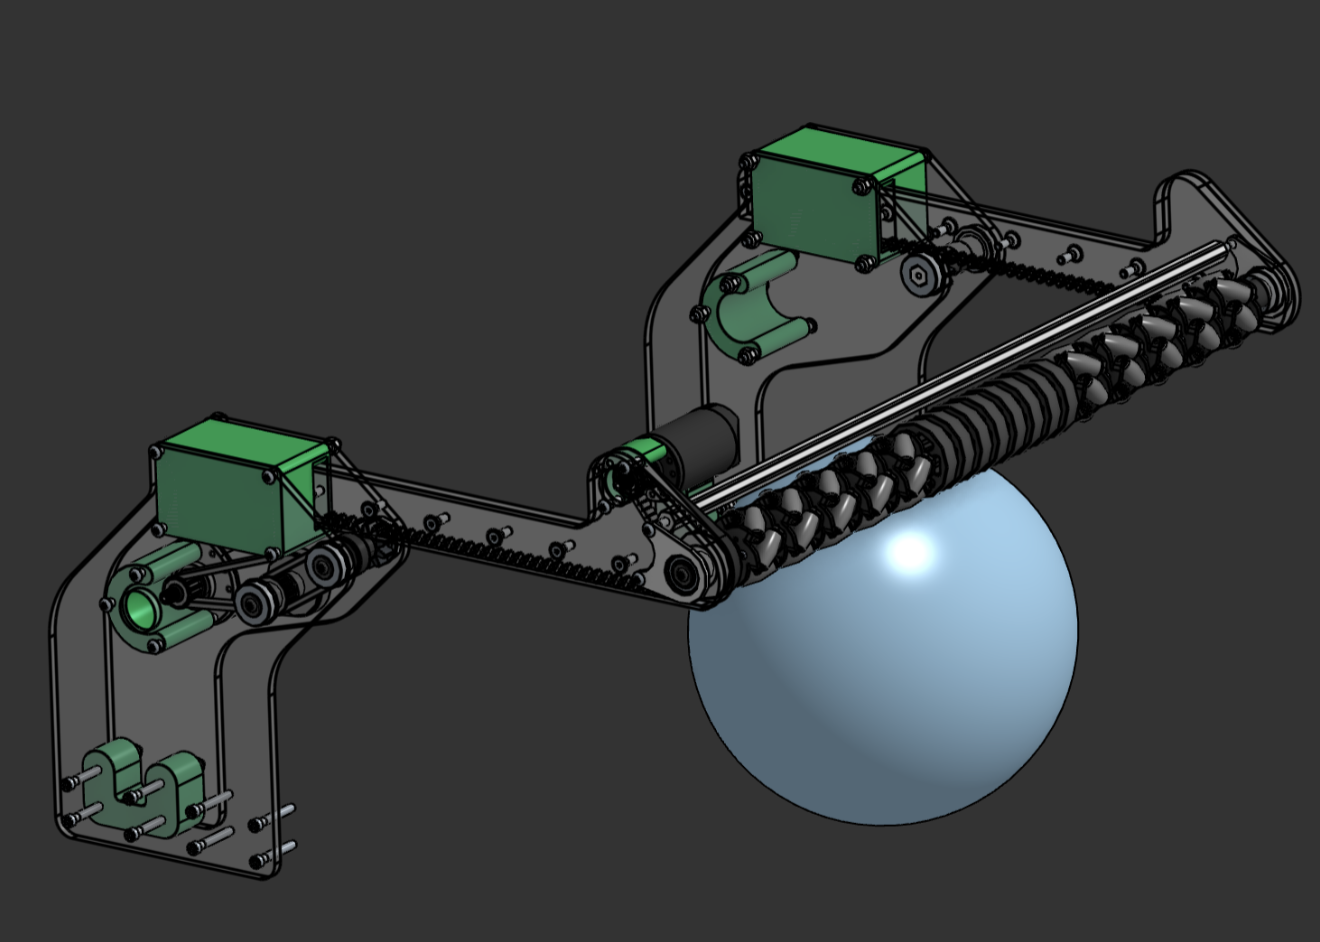
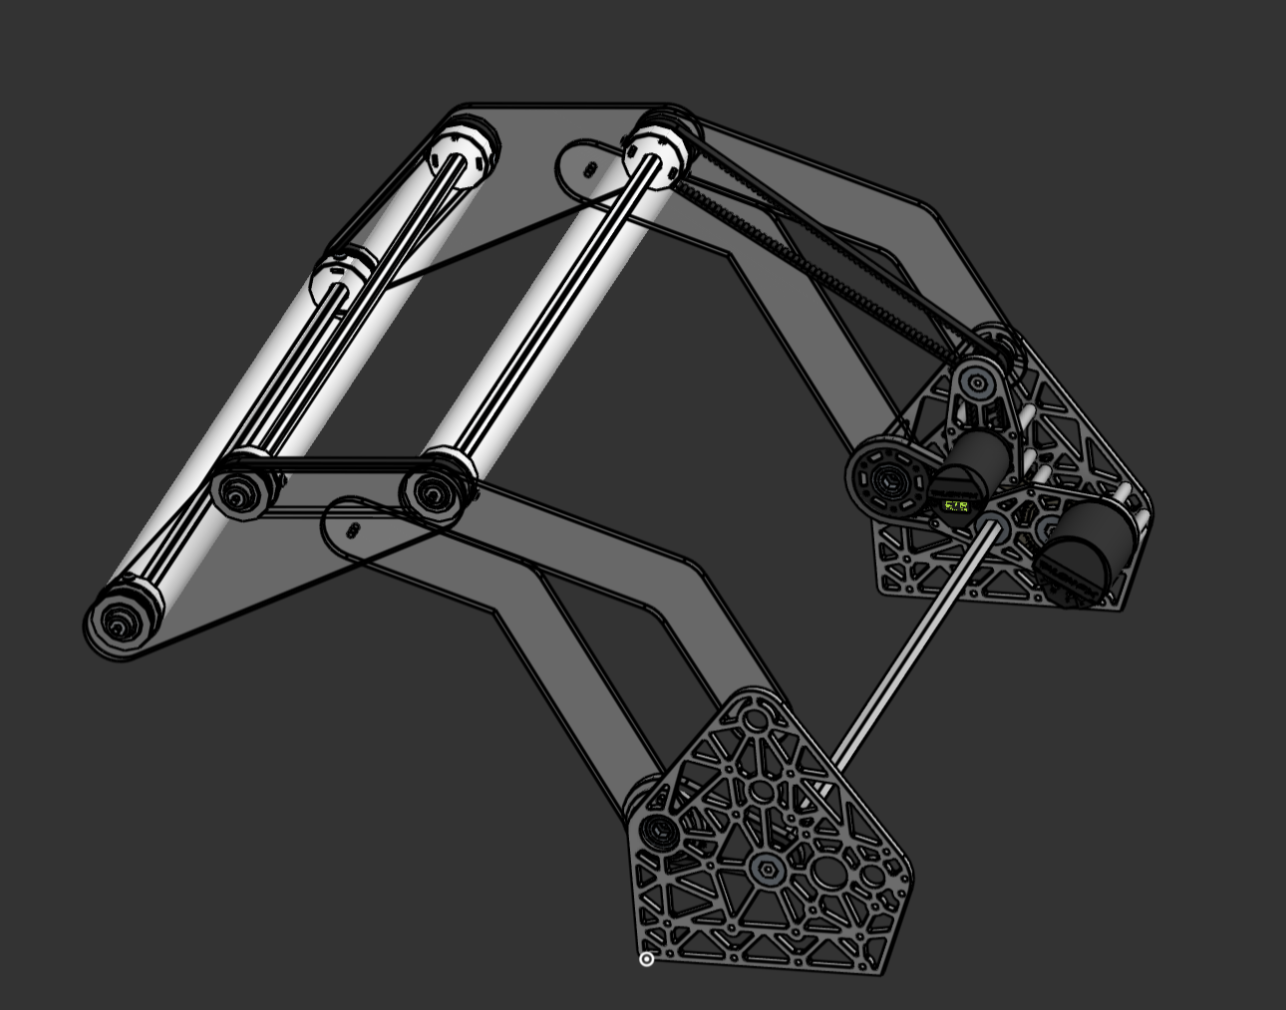
Designed a four-bar linkage intake mechanism for an FRC competition robot, allowing the roller assembly to move through a controlled deployment path while maintaining the orientation needed to acquire game pieces effectively.
I developed the mechanism in CAD and integrated the four-bar geometry, belt-driven rollers, motors, gear reductions, bearings, and structural plates into a compact assembly. The design required careful attention to linkage geometry, packaging, motion range, torque transmission, and subsystem integration. I also worked through belt and pulley placement so the intake rollers could stay powered throughout the mechanism's motion while fitting within the robot's overall structure.
Design Goals
- Deploy the intake through a controlled motion path
- Maintain a useful roller orientation throughout deployment
- Package within the available robot volume
- Provide adequate motion range
- Transmit power reliably to the intake rollers
- Integrate with the robot's surrounding structure and mechanisms
- Remain mechanically rigid under competition use
Mechanical Design
- Four-bar linkage geometry
- Belt-driven intake rollers
- Motors
- Gear reductions
- Pulleys and belts
- Bearings
- Pivot shafts
- Structural side plates
- Mounting hardware
Drive System
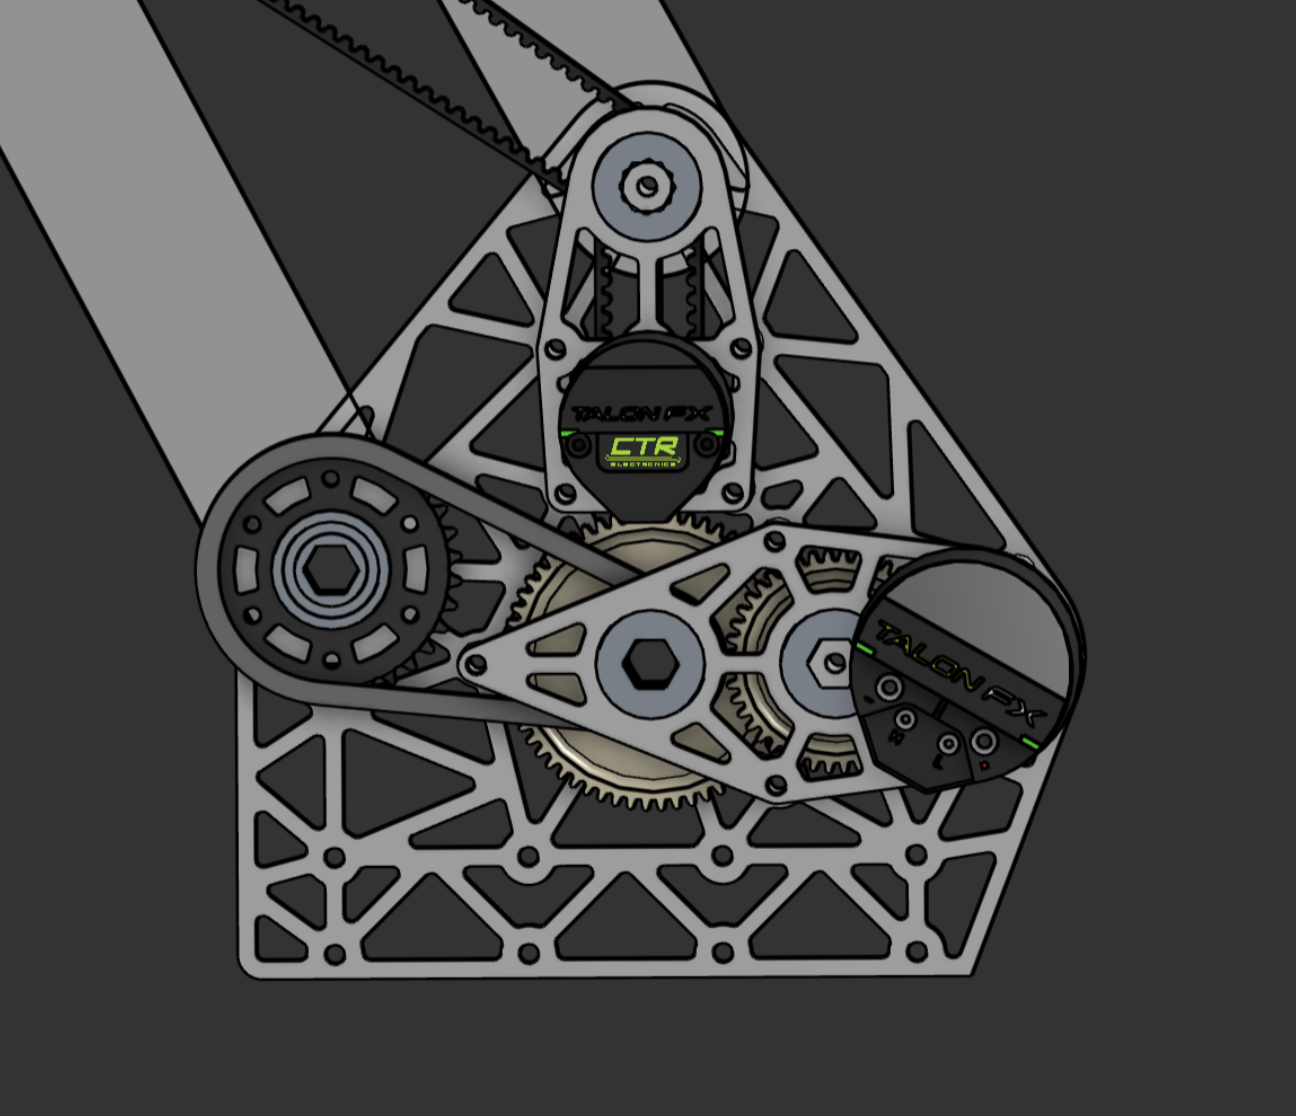
Detail of the belt and gear reduction driving the intake rollers through the linkage's motion.